
Several control units are applied to electronically controlled vehicles. These units perform each control with informations from various sensors. Thus, sharing signal information from sensors is needed, so CAN communication type whose communication speed is high and insensitive to electrical noise by spark generation is adopted to controlling power-train(TCM, ECM, CLUSTER,VDC,4WD,EAS,SAS, EPS)
CAN communication consists of CAN BUS HIGH, CAN BUS LOW and two 120Ω resistances in circuit.
TCM set this code If detected error in CAN communication line. (MIL OFF)
Item | Detecting Condition | Possible Cause |
DTC Strategy |
•
Check function |
•
CAN communication line open of TCM side
•
CAN communication line short of TCM side
•
ECM
•
CLUSTER
•
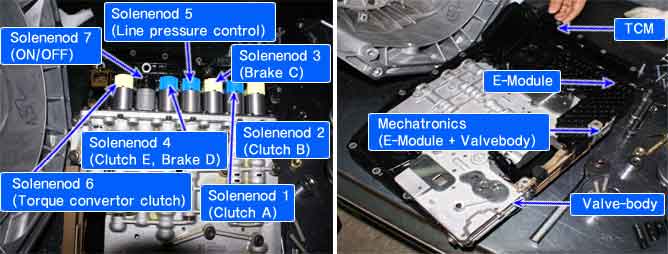
Mechatronics(E-module + Valvebody) |
Enable Conditions |
•
Battery voltage > 9V
•
0.5 second after IG ON | |
Threshold Value |
•
CAN BUS가 OFF (Not properly work CAN BUS)
•
CAN time-out | |
Diagnostic Time |
•
0.56 second | |
Fail Safe |
•
Maximum line pressure control (D : 14kg/㎠, R : 20kg/㎠)
•
Vehicle speed is subtituted wheel speed
•
Release "Shift lock"
•
Maintain present gear position at fault detecting.
•
Fixed at 3rd gear after stop
•
No control Torque convertor clutch
•
No learning control (Priority : 3) |
